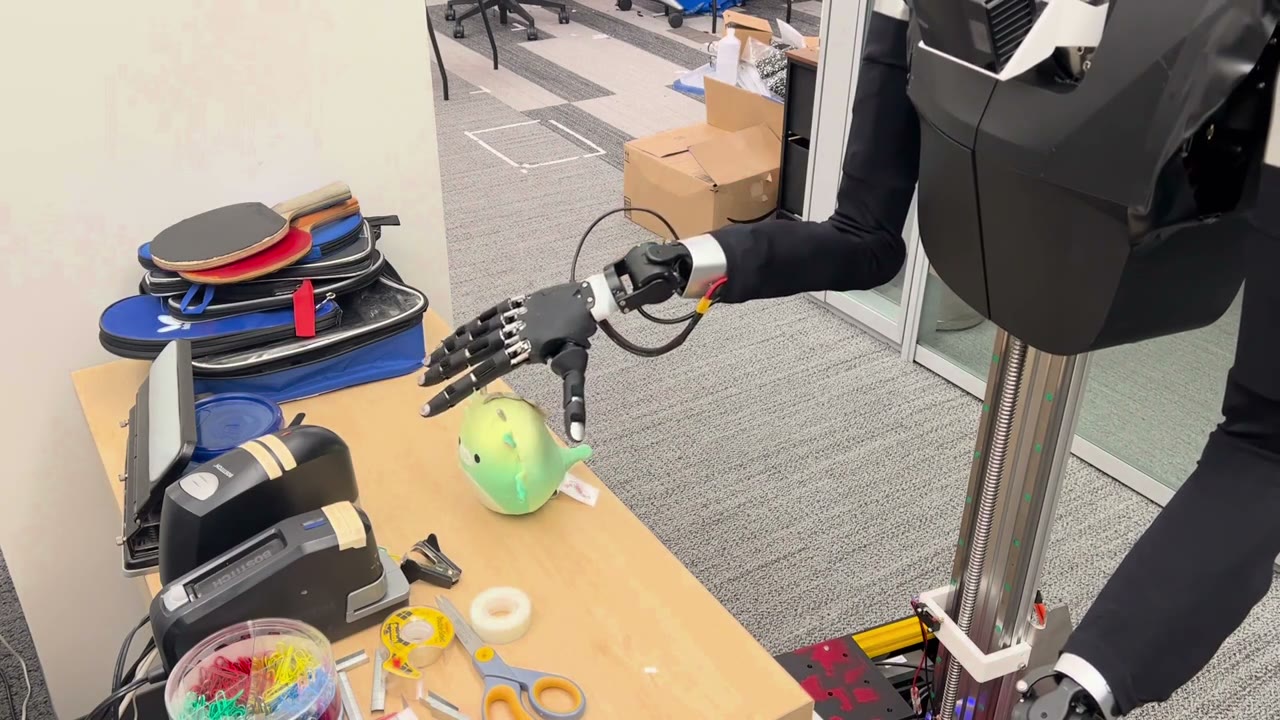
Whole-body teleoperation
Tracked wrist motion commands the end effectors, while finger tracking controls the hands. The base and lift move as part of the same coordinated system.
Anonymous ICRA submission
An Open-Source Wheeled Humanoid for Dexterous Loco-manipulation
YOR-Dex combines an omnidirectional mobile base, a vertical lift, two seven-degree-of-freedom arms, and interchangeable dexterous hands. Onboard sensing and compute support coordinated whole-body teleoperation, navigation, and autonomous manipulation learned from robot and human demonstrations.
Scroll through the robot and inside its base.
Loading hardware animation…
Scroll down to disassemble · Scroll up to reassemble
The controller coordinates the base, lift, and arms to track end-effector targets in the world frame. Onboard mapping supports movement through changing environments.
Tracked wrist motion commands the end effectors, while finger tracking controls the hands. The base and lift move as part of the same coordinated system.
Synchronized map and camera views show the robot navigating around obstacles while updating its map.
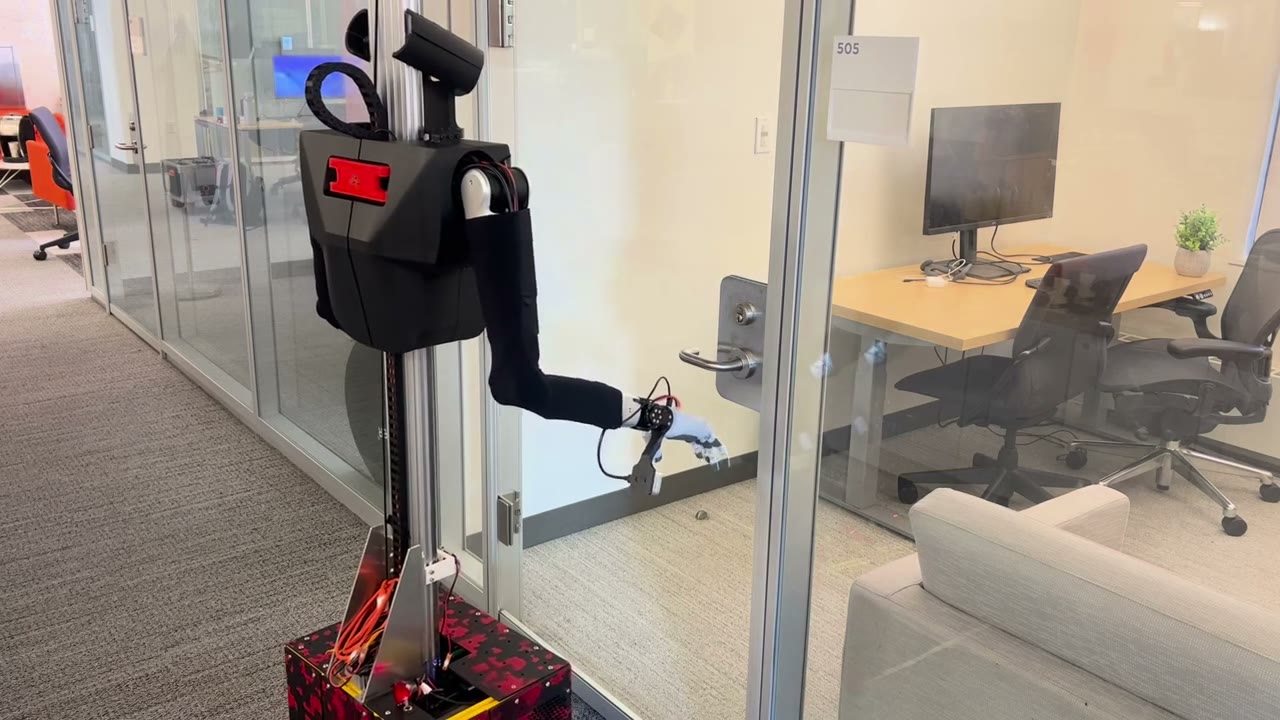
Cup pickup and door opening learned from whole-body teleoperation.
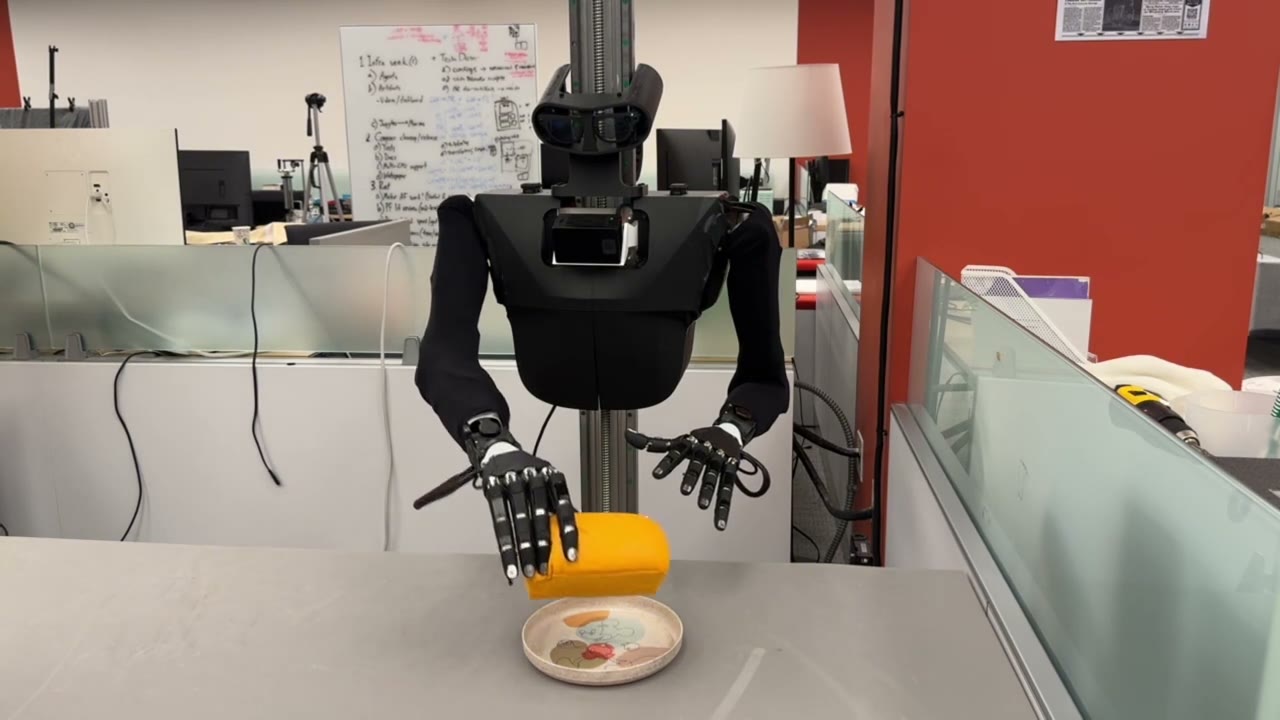
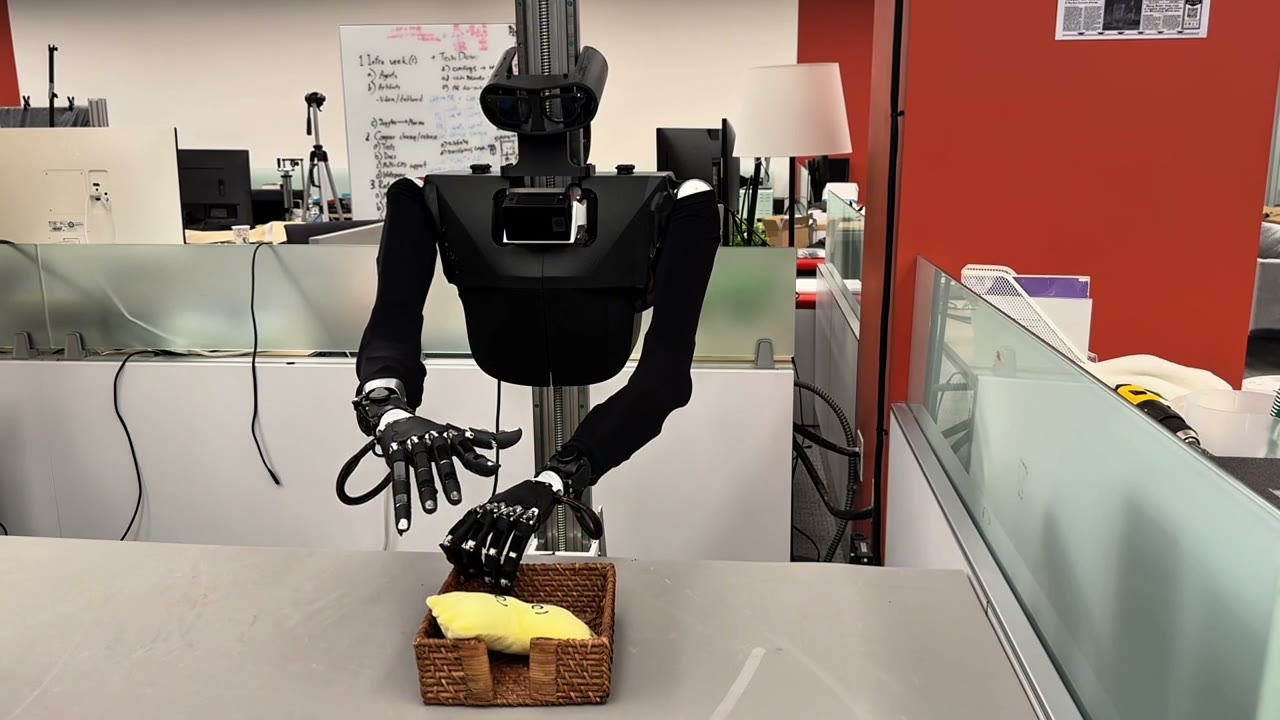
Six household tasks learned from robot-free human demonstrations, shown at normal speed.
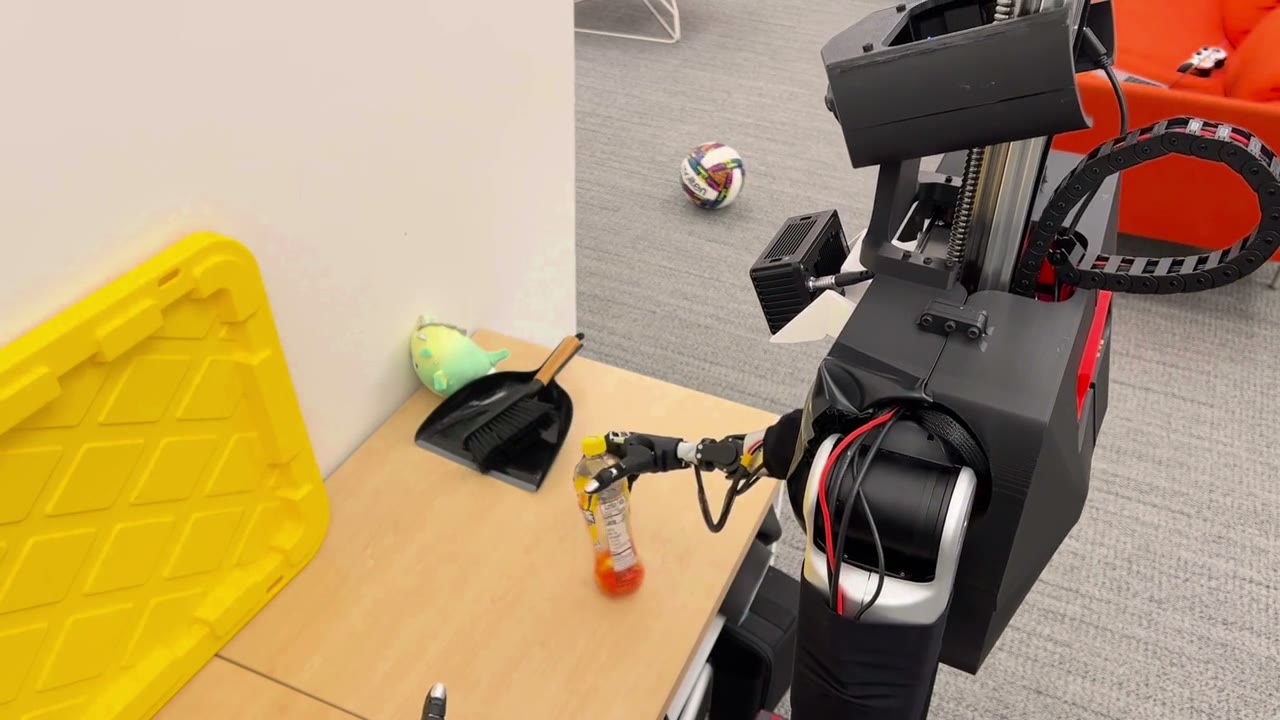
Grasping six objects using Human Universal Grasping, a pretrained RGB-D model.
YOR-Dex returns to the same end-effector target after navigating through the lab.
9.4 ± 4.0 mm
Mean 3D end-effector return error
The bill of materials lists the platform’s parts.